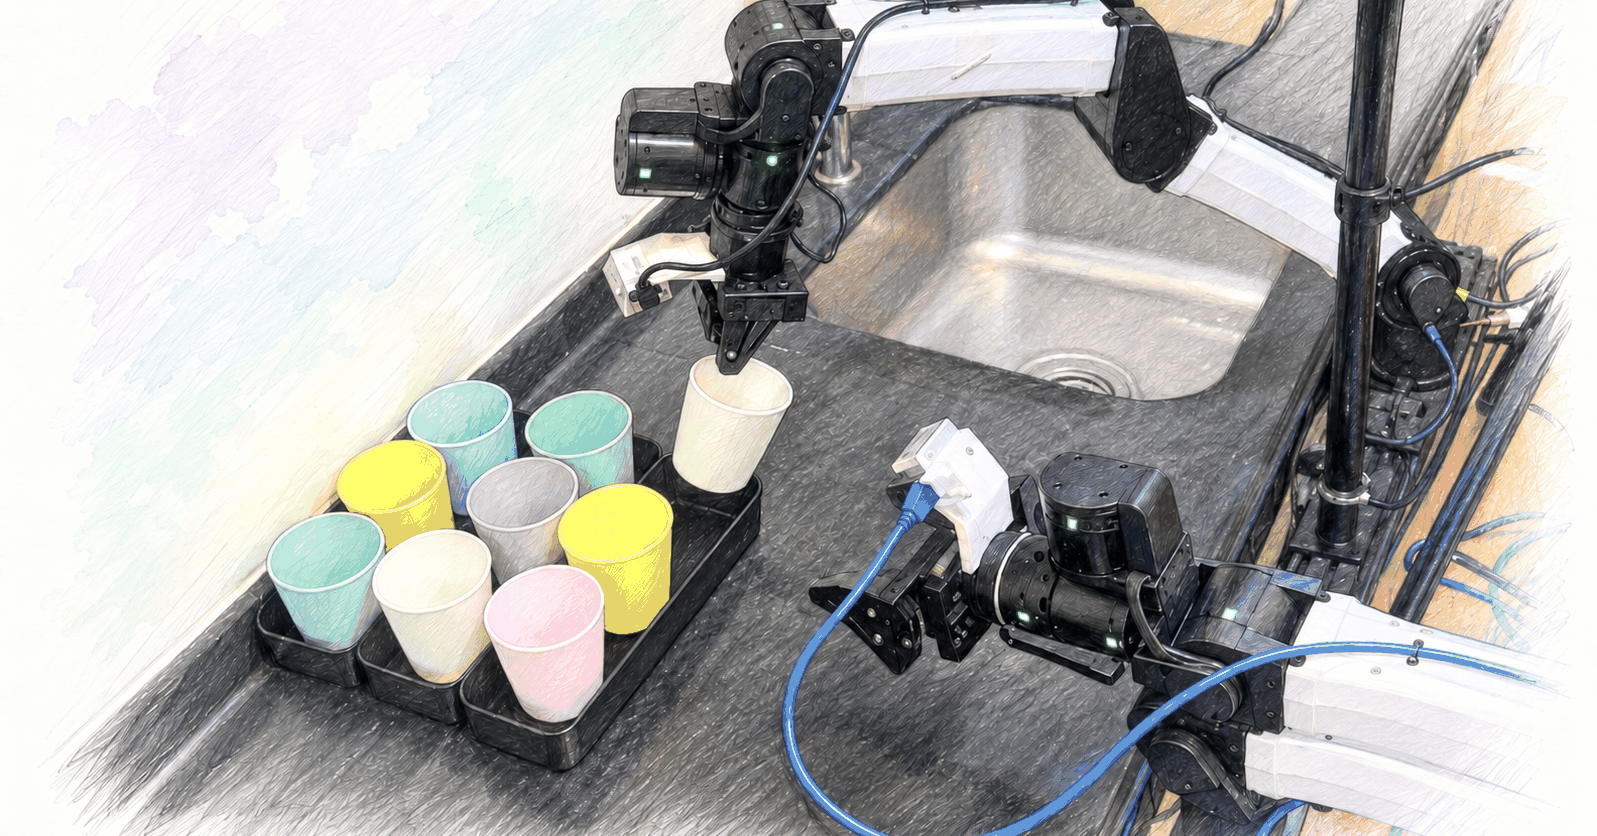01. Egocentric Data
Real work in real
world environments
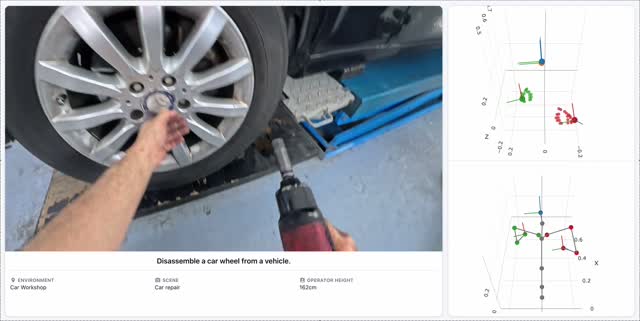
Capture the most diverse egocentric data from real workplaces. Every frame includes hand and body pose, depth, and subtask annotations. This makes egocentric video directly usable for robotics.
- Hand and body pose
- Depth and subtask annotations
02. Robot Data
Real robots in
real workplaces
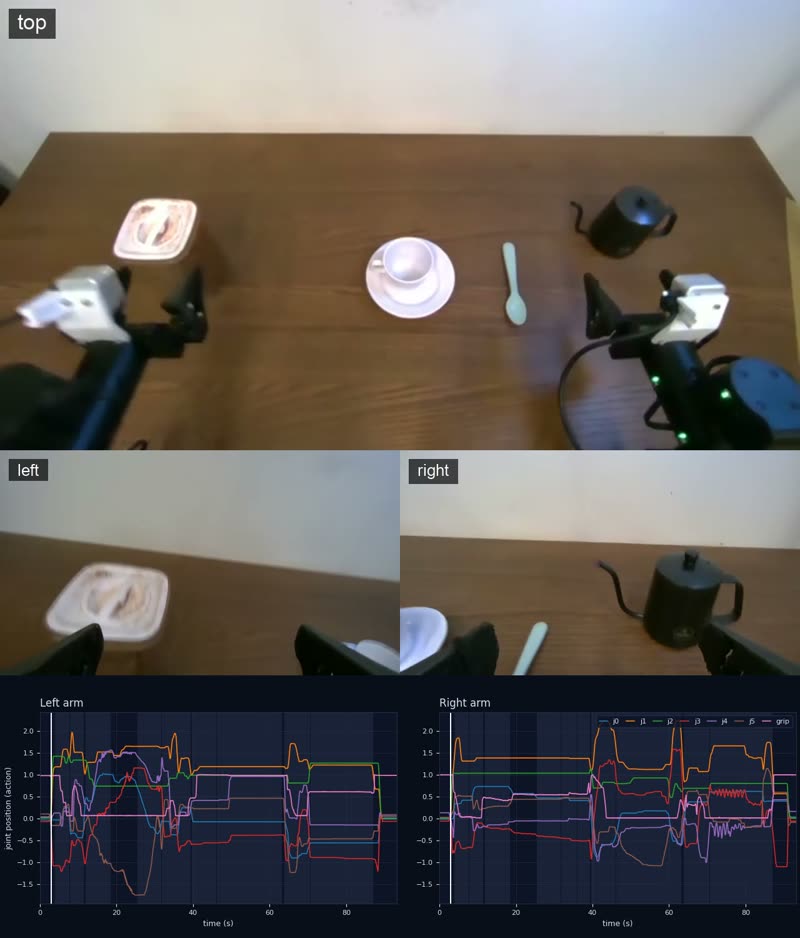
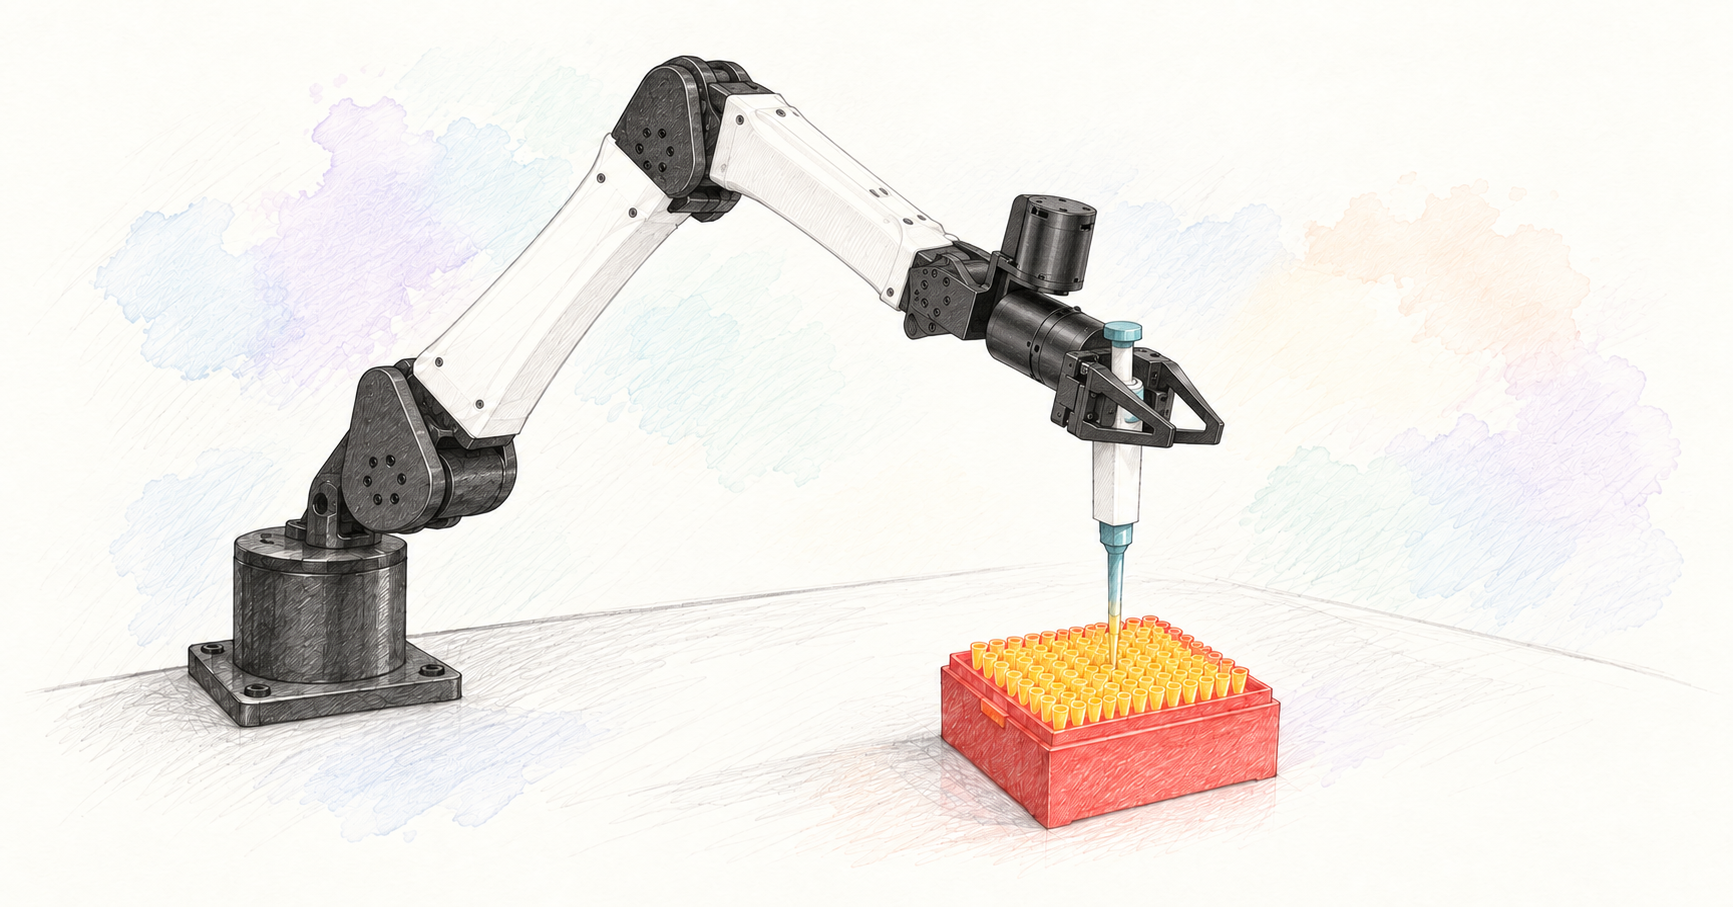
Collect robot trajectories directly in real workplaces through our network of industry partners. High-quality, embodiment-specific real-world data to fine-tune on top of foundation models.
- Robot trajectoriesReal workplaces
- Robot Data for Fine-Tuning
03. Harness
Human-in-the-Loop
Rollouts and Evals
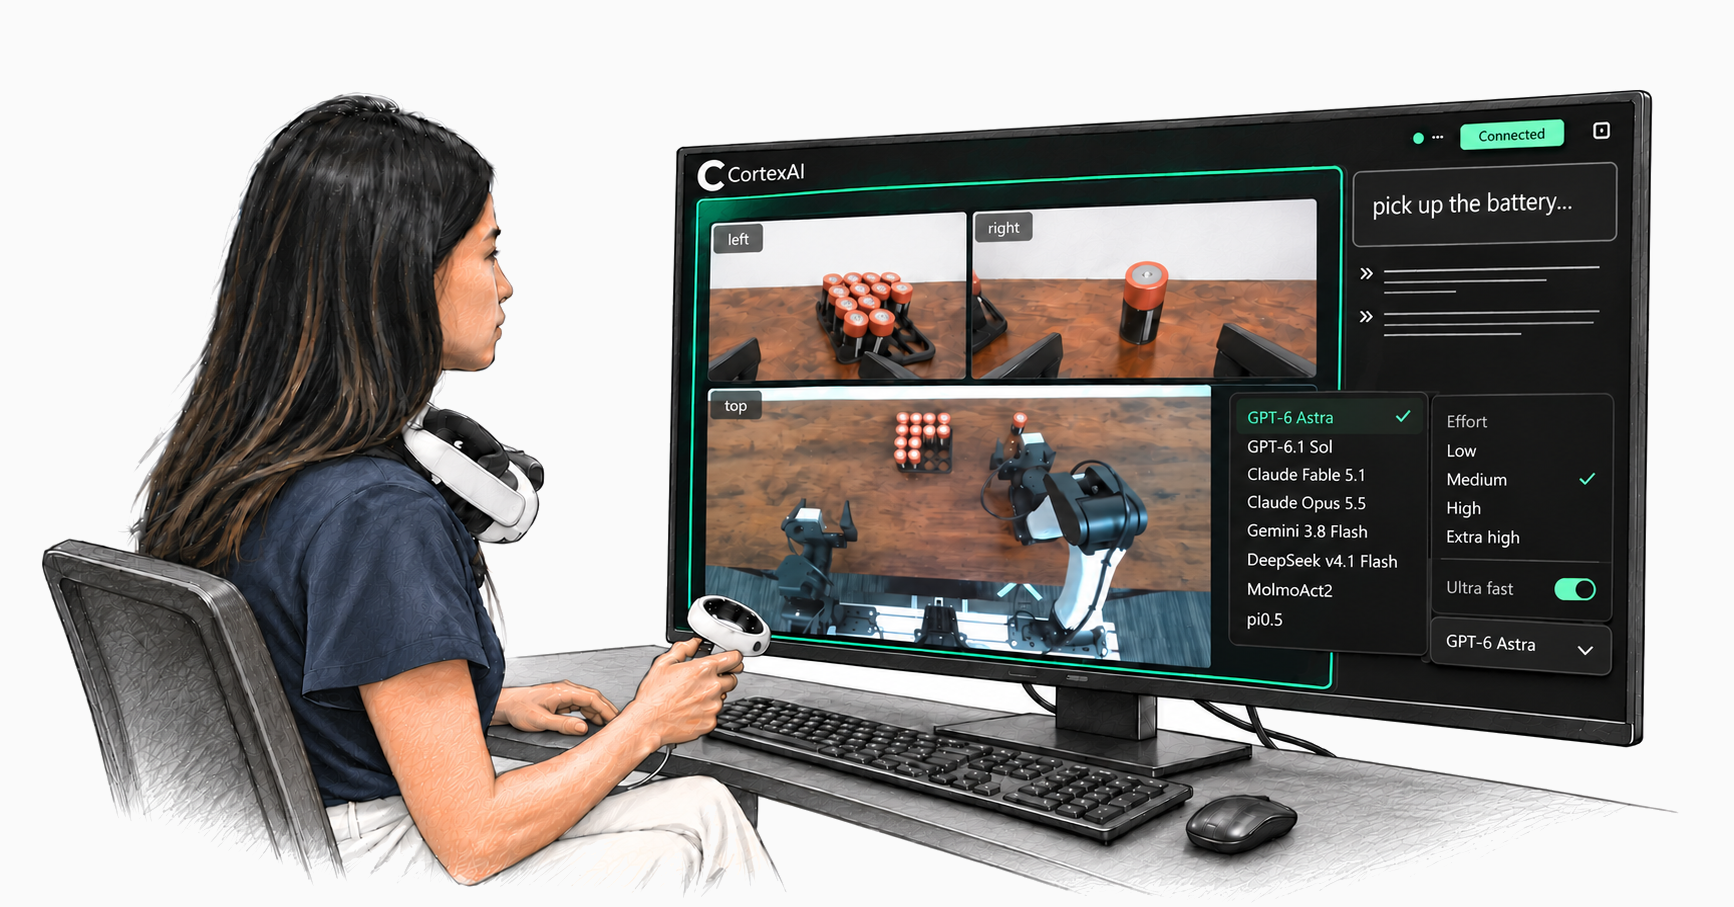
Support real-world rollouts with human oversight. Capture recovery data for edge cases and create a continuous data flywheel. Every deployment adds experience that feeds back into training.
- Human oversight
- Recovery data for edge cases